About the team
Students building autonomous flight
Washington Aerial Robotics is a multidisciplinary engineering team of students and faculty at the University of Washington in Seattle. We design, manufacture, and test autonomous drones — with a main focus on quadcopters — giving members hands-on experience across software development, systems engineering, 3D modeling, hardware manufacturing, guidance, navigation & control, and pilot operation.
Our purpose is simple: give the UW engineering community real opportunities to learn how autonomous aerial systems are built — not in theory, but by putting drones in the air.
The competition
The International Aerial Robotics Competition
Washington Aerial Robotics participates in the International Aerial Robotics Competition (IARC), one of the most long-running and technically challenging autonomous aerial robotics contests in the world. It is specifically designed to push the limits of what autonomous flying robots can do.
Current challenge
Mission 10
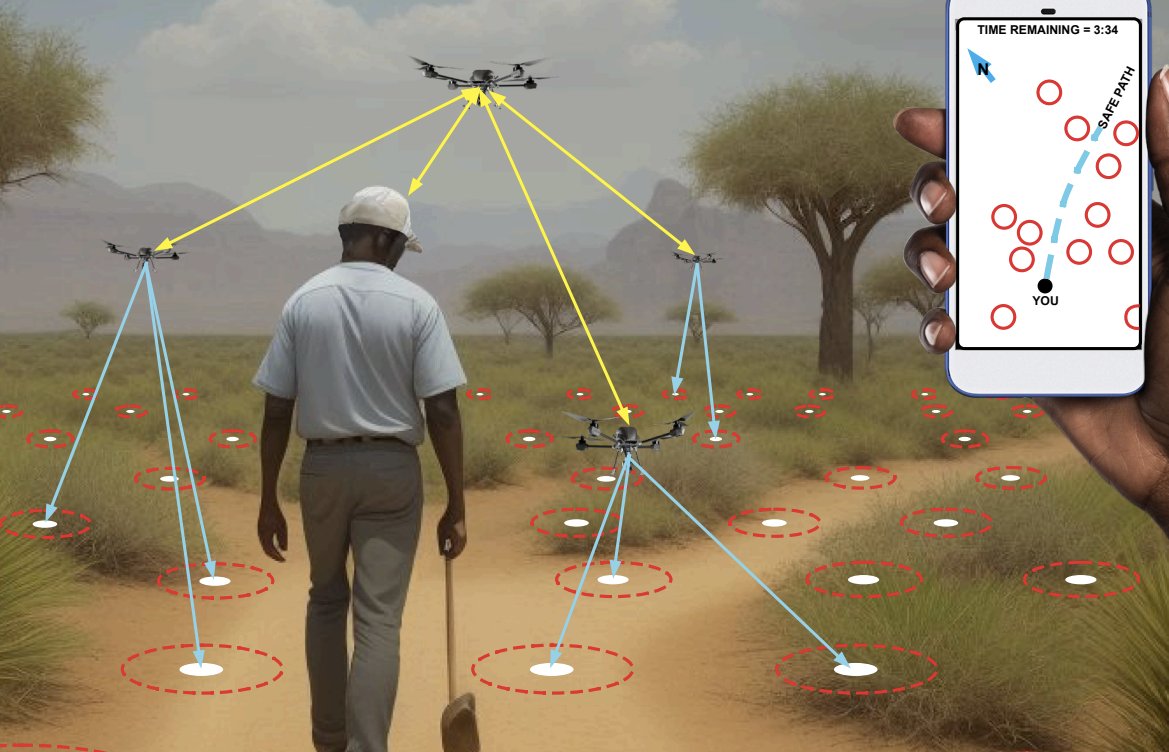
Mission 10 of the IARC focuses on a team of four autonomous drones working together to map a simulated minefield and determine the safest and most efficient path through it. Instead of just detecting mines, the mission emphasizes real-time coordination, communication, and decision-making as a swarm.
The drones must share data, build a map of the environment, avoid obstacles, and quickly identify an optimal route a person could safely follow — all without human control. Scoring is based on how safe and efficient the chosen path is, how quickly the solution is generated, and how well the system avoids errors such as missed hazards.
How we are organized
Mechanical
Testbed and structures design, propulsion integration, and hardware system integration.
Avionics
Flight-controller, power-supply, and ESC PCB design, plus electrical systems integration.
Firmware
Peripherals, flight-control integration, the ground station, comms, and parameter tuning.
Autonomy
Flight and user trajectory planning, multi-agent coordination, and flight-computer software.
Perception
Camera integration, visual detection, SLAM, and mapping.
Business
Onboarding, outreach, grants and sponsorships, budgeting, and membership policy.